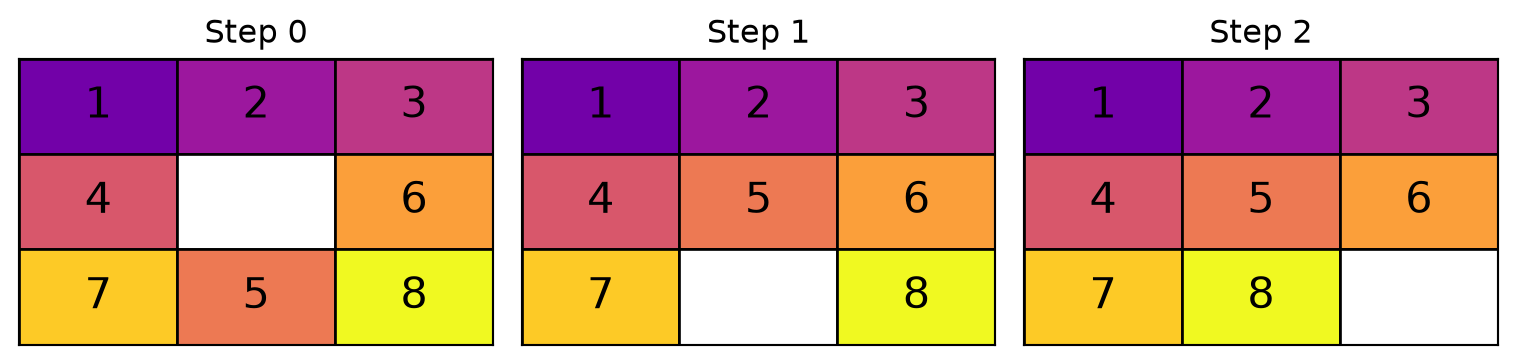
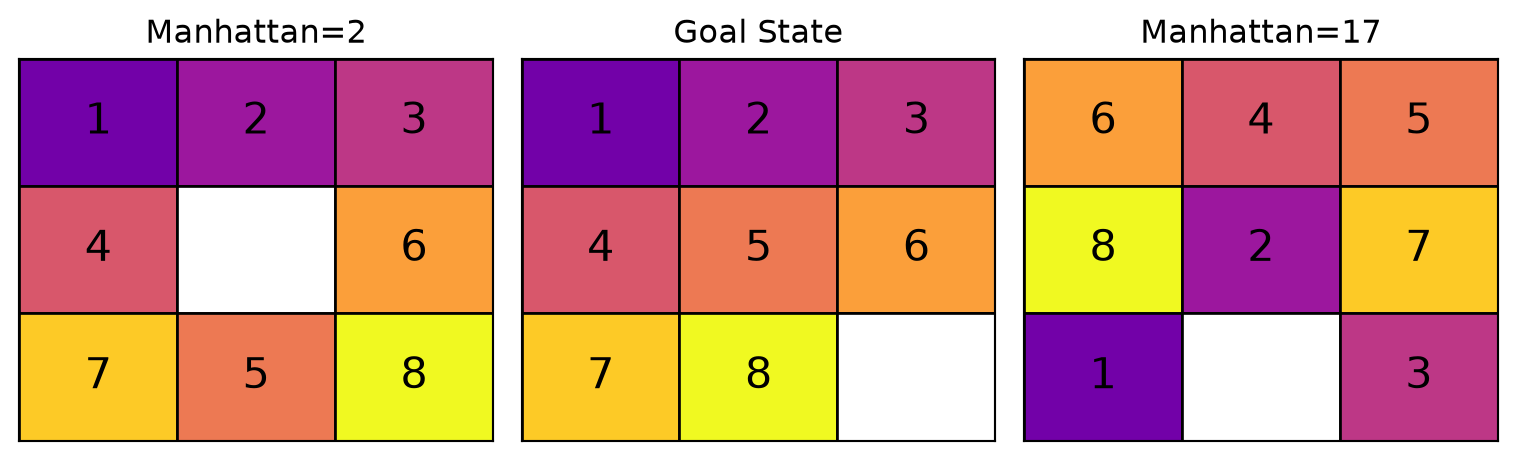
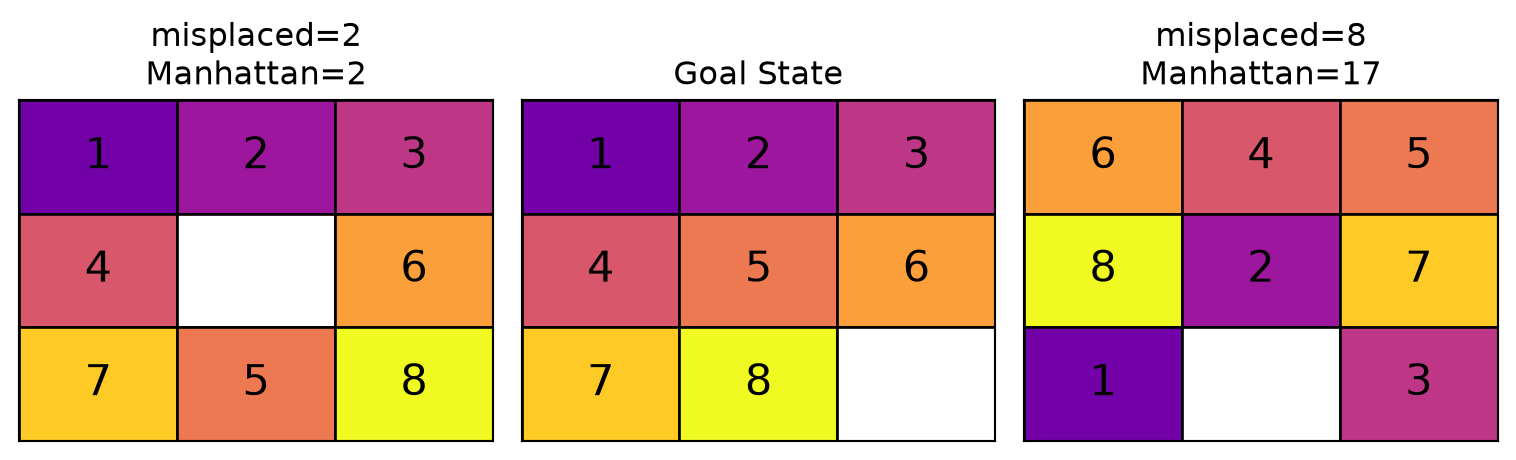
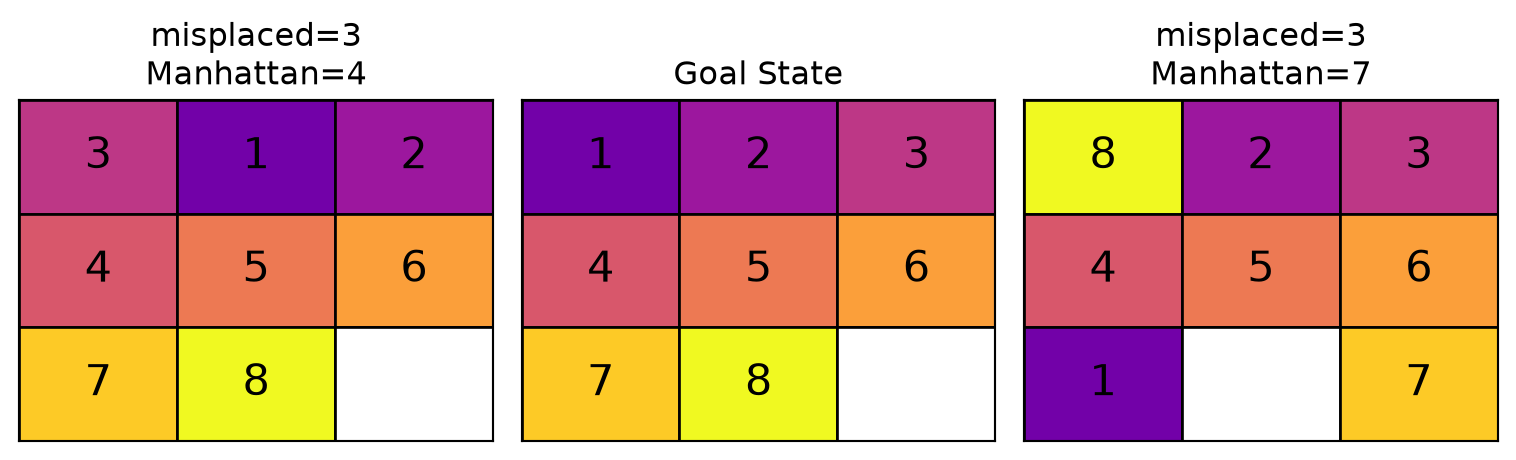
import random
from collections import deque

import matplotlib.pyplot as plt
import numpy as np

random.seed(58)

def is_solvable(tiles):
    # Count the inversions in the flattened list of tiles (excluding the blank space).
    # Assumption: board is square and width is odd.
    inversions = 0
    for i in range(len(tiles)):
        for j in range(i + 1, len(tiles)):
            if tiles[i] != 0 and tiles[j] != 0 and tiles[i] > tiles[j]:
                inversions += 1
    return inversions % 2 == 0

def generate_solvable_board():
    # Generate a random board configuration that is guaranteed to be solvable
    tiles = list(range(9))
    random.shuffle(tiles)
    while not is_solvable(tiles):
        random.shuffle(tiles)

    return tuple(tiles)

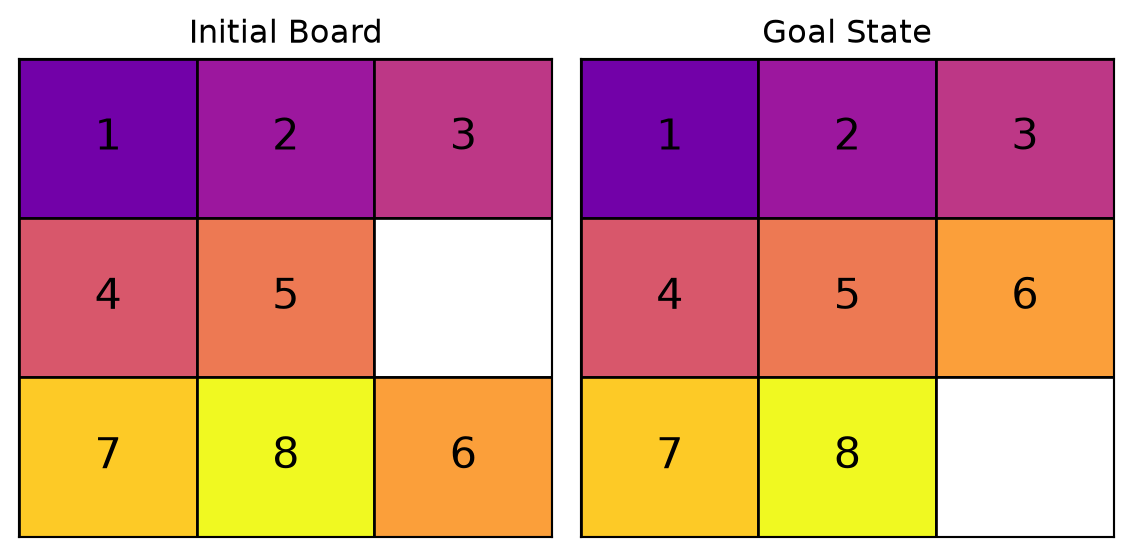
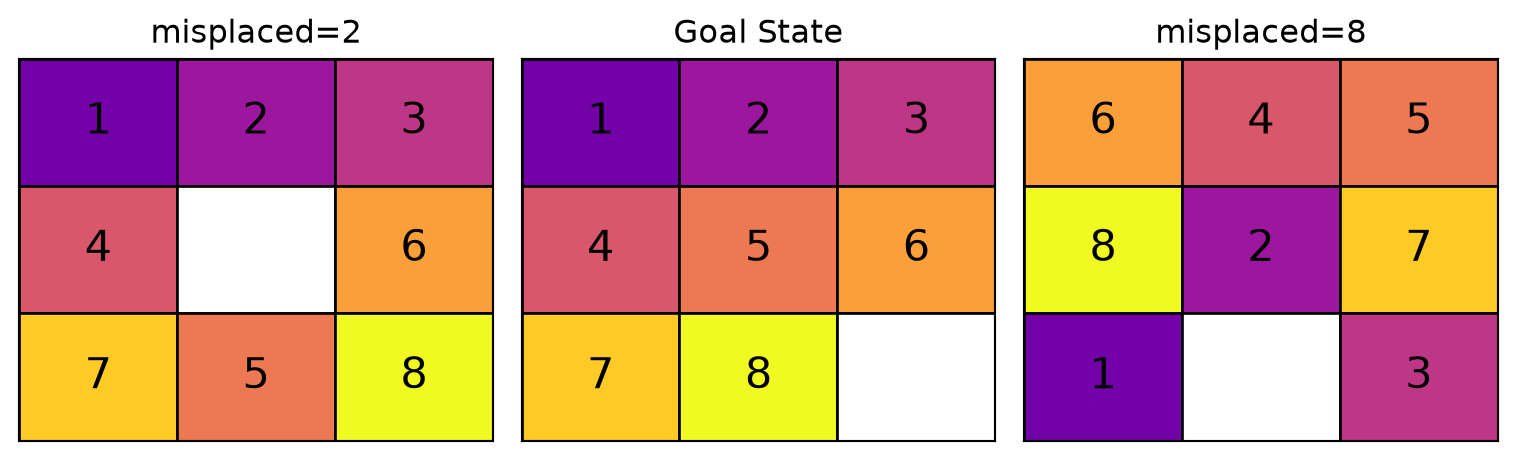
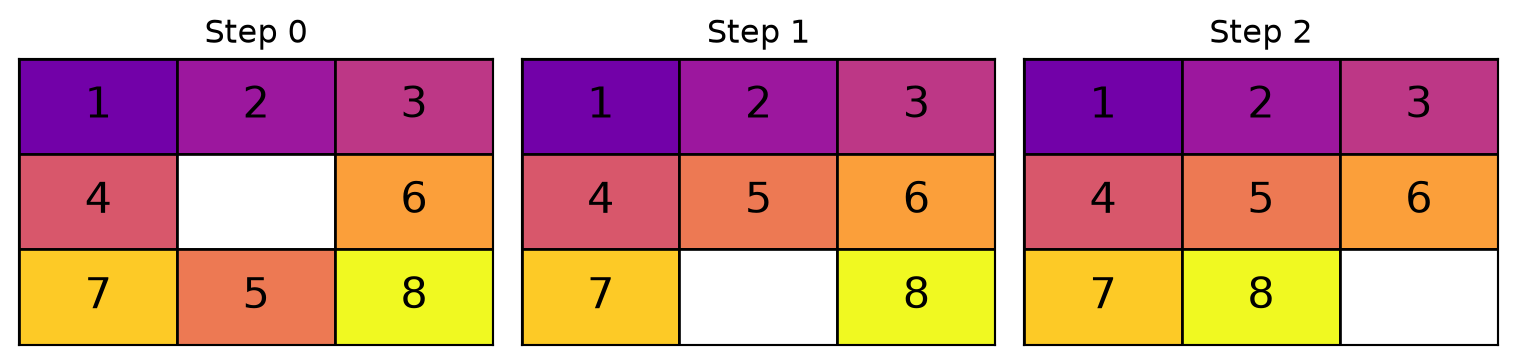
def plot_board(board, title, num_pos, position):
    ax = plt.subplot(1, num_pos, position)
    ax.set_title(title)
    ax.set_xticks([])
    ax.set_yticks([])

    board = np.array(board).reshape(3, 3).tolist() # Reconfigure the grid to be 3x3

    # Use a color map to display the numbers
    cmap = plt.cm.plasma
    norm = plt.Normalize(vmin=-1, vmax=8)

    for i in range(3):
        for j in range(3):
            tile_value = board[i][j]
            color = cmap(norm(tile_value))
            ax.add_patch(plt.Rectangle((j, 2 - i), 1, 1, facecolor=color, edgecolor='black'))
            if tile_value == 0:
                ax.add_patch(plt.Rectangle((j, 2 - i), 1, 1, facecolor='white', edgecolor='black'))
            else:
                ax.text(j + 0.5, 2 - i + 0.5, str(tile_value),
                        fontsize=16, ha='center', va='center', color='black')

    ax.set_xlim(0, 3)
    ax.set_ylim(0, 3)

def is_empty(frontier):
    """Checks if the frontier is empty."""
    return len(frontier) == 0

def is_goal(state, goal_state):
    """Determines if a given state matches the goal state."""
    return state == goal_state

def expand(state):
    """Generates successor states by moving the blank tile in all possible directions."""
    size = int(len(state) ** 0.5)  # Determine puzzle size (3 for 8-puzzle, 4 for 15-puzzle)
    idx = state.index(0)  # Find the index of the blank tile represented by 0
    x, y = idx % size, idx // size  # Convert index to (x, y) coordinates
    neighbors = []

    # Define possible moves: Left, Right, Up, Down
    moves = [(-1, 0), (1, 0), (0, -1), (0, 1)]
    for dx, dy in moves:
        nx, ny = x + dx, y + dy
        # Check if the new position is within the puzzle boundaries
        if 0 <= nx < size and 0 <= ny < size:
            n_idx = ny * size + nx
            new_state = list(state)
            # Swap the blank tile with the adjacent tile
            new_state[idx], new_state[n_idx] = new_state[n_idx], new_state[idx]
            neighbors.append(tuple(new_state))
    return neighbors

def print_solution(solution):
    """Prints the sequence of steps from the initial to the goal state."""
    size = int(len(solution[0]) ** 0.5)
    for step, state in enumerate(solution):
        print(f"Step {step}:")
        for i in range(size):
            row = state[i*size:(i+1)*size]
            print(' '.join(str(n) if n != 0 else ' ' for n in row))
        print()

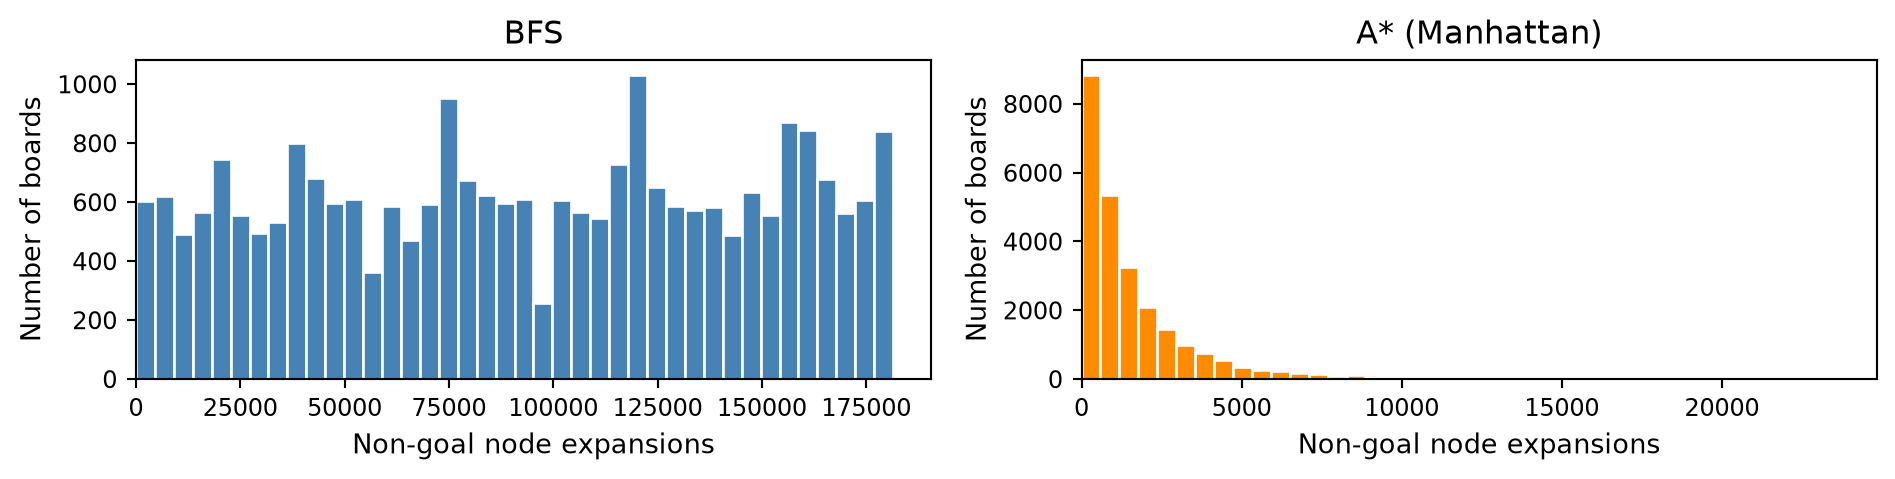
def bfs(initial_state, goal_state):

    frontier = deque()  # Initialize the queue for BFS
    frontier.append((initial_state, []))  # A node: (state, preceding states)

    reached = {initial_state}

    expanded = 0  # Count non-goal nodes whose successors are generated

    while not is_empty(frontier):
        current_state, path = frontier.popleft()

        if is_goal(current_state, goal_state):
            print(f"Nodes expanded: {expanded}")
            return path + [current_state]  # Return the successful path

        expanded += 1

        for neighbor in expand(current_state):
            if neighbor not in reached:
                reached.add(neighbor)
                frontier.append((neighbor, path + [current_state]))

    return None

def dfs(initial_state, goal_state):

    frontier = [(initial_state, [])]  # A node: (state, preceding states)

    reached = {initial_state}

    expanded = 0

    while not is_empty(frontier):
        current_state, path = frontier.pop()

        if is_goal(current_state, goal_state):
            print(f"Nodes expanded: {expanded}")
            return path + [current_state]  # Return the successful path

        expanded += 1

        for neighbor in expand(current_state):
            if neighbor not in reached:
                reached.add(neighbor)
                frontier.append((neighbor, path + [current_state]))

    return None